Portrait of Javed Ahmad
Rome, Italy Robotics · 3D Vision

3D Vision & Robotics Researcher

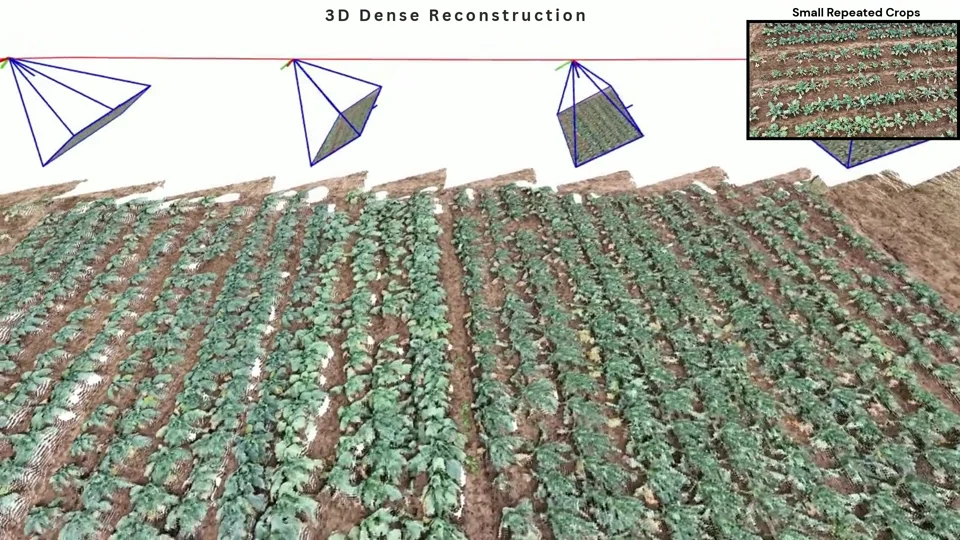
I develop autonomous UAV perception systems for agricultural mapping, combining visual localization, SLAM, and dense 3D reconstruction. At the Italian Institute of Technology, I worked on 3D Gaussian Splatting for robotic teleoperation, autonomous artifact scanning, and LiDAR–camera fusion for 3D detection. I earned my Ph.D. at the University of Genoa and the Italian Institute of Technology.

Focus

SLAM, dense 3D mapping, multimodal perception, and robotic autonomy.

Highlights

AgroMap3D accepted at WACV 2027. First prizes at VISUM 2021 and EEML 2020.

Research Areas

3D Mapping and Reconstruction

Visual localization, SLAM, structure from motion, and neural scene representations for field-scale mapping and real-time visualization.
Robotic Perception and Autonomy

UAV sensing and mission control, 6-DoF object pose estimation, robot motion planning, and automated 3D scanning.

Multimodal 3D Vision

Learning-based fusion of camera and LiDAR data for 3D detection, and geometric methods for object localization across multiple views.
Flagship Systems

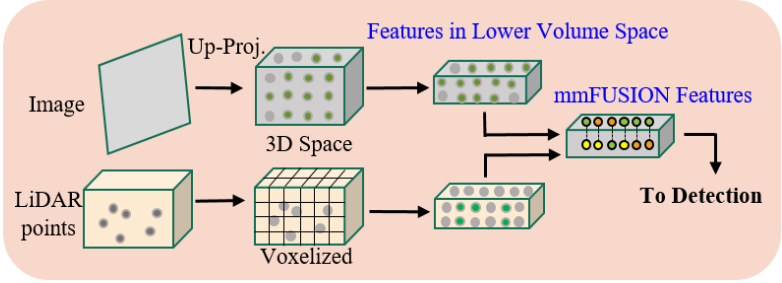
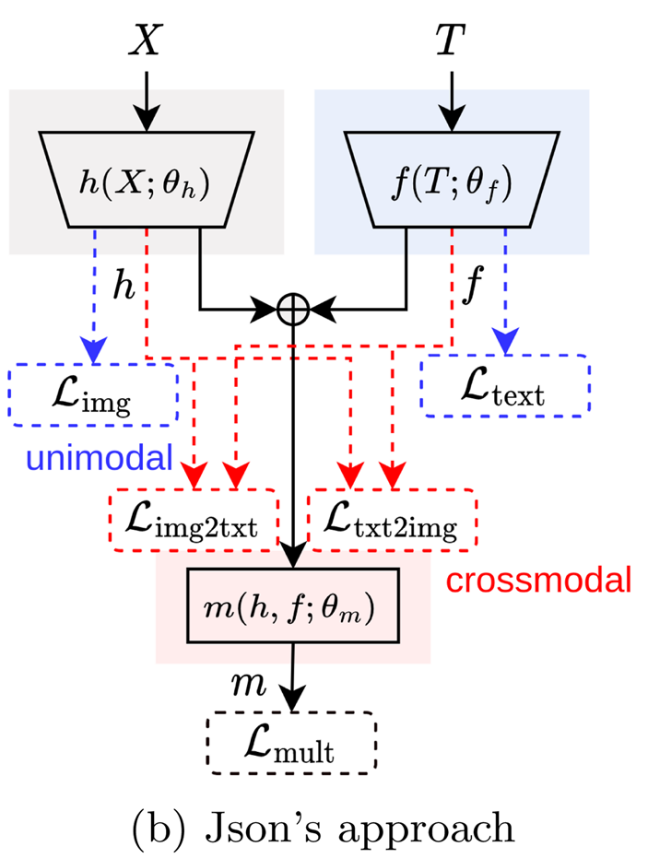
Diagram of the mmFUSION LiDAR and camera fusion architecture

Multimodal 3D Scene Perception

LiDAR–camera fusion for 3D object detection.

mmFUSION publication

Selected Publications

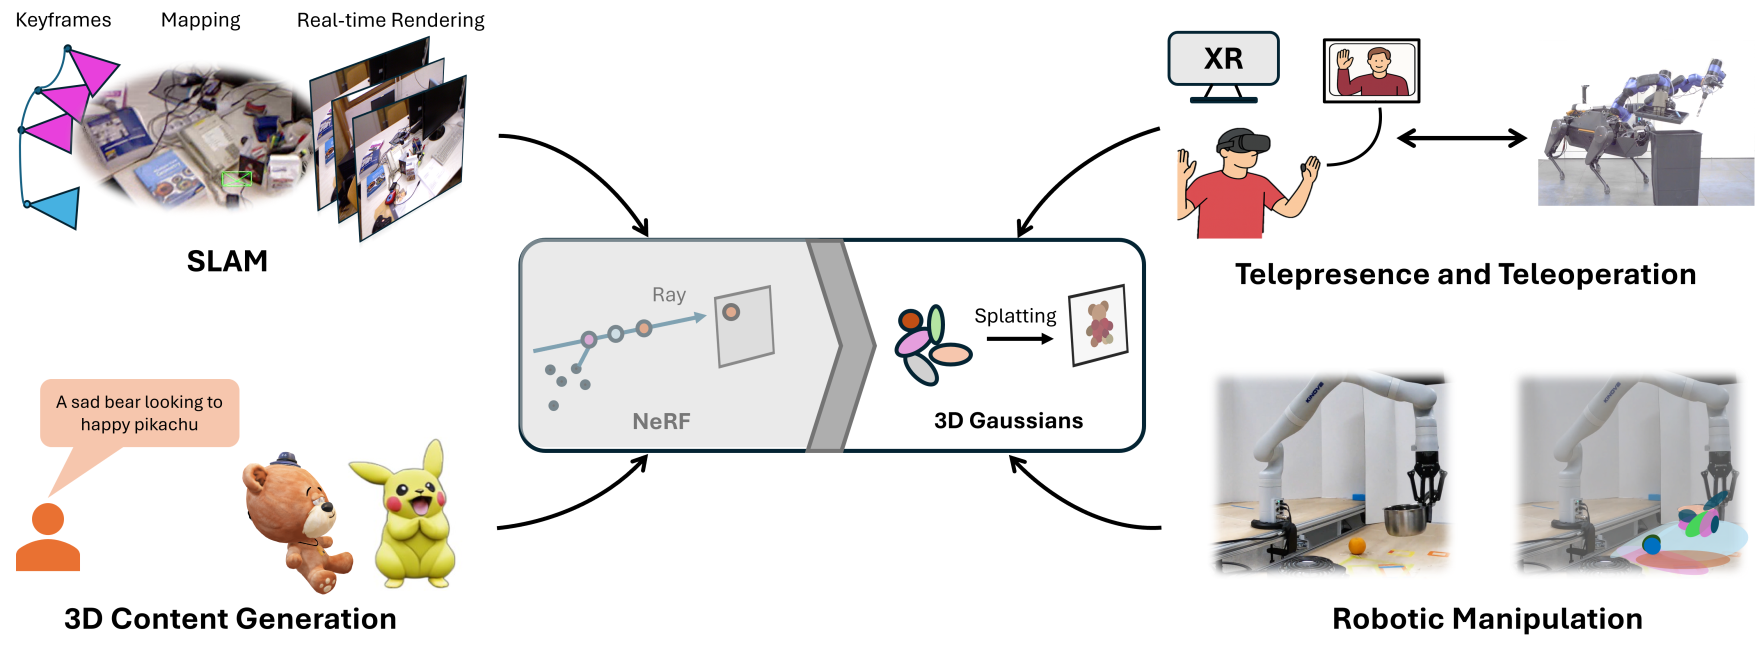
Open the Fields to Splats survey figure

arXiv preprint · 2025

From Fields to Splats: A Cross-Domain Survey of Real-Time Neural Scene Representations

Javed Ahmad et al.

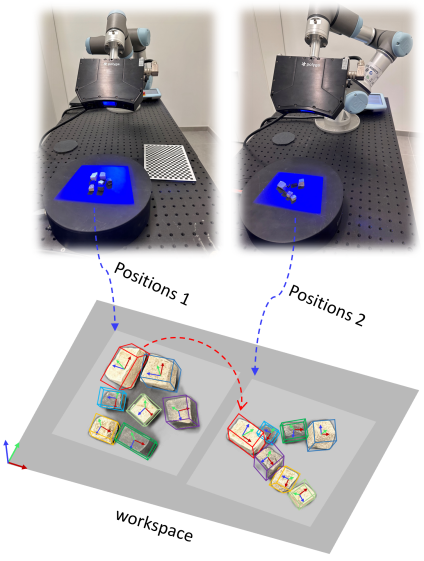
Open the AAPOE experimental setup figure

IEEE/ASME MESA · 2024

AAPOE: Automated Artifacts Position and Orientation Estimation in Cultural Heritage

Javed Ahmad et al.

Open the mmFUSION method diagram

arXiv preprint · 2023

mmFUSION: Multi-modal Fusion for 3D Object Detection

Javed Ahmad and Alessio Del Bue

Open the fashion outfit retrieval figure

Machine Vision and Applications · 2023

Fill in the Blank for Fashion Complementary Outfit Product Retrieval: VISUM Summer School Competition

Eduardo Castro et al., including Javed Ahmad

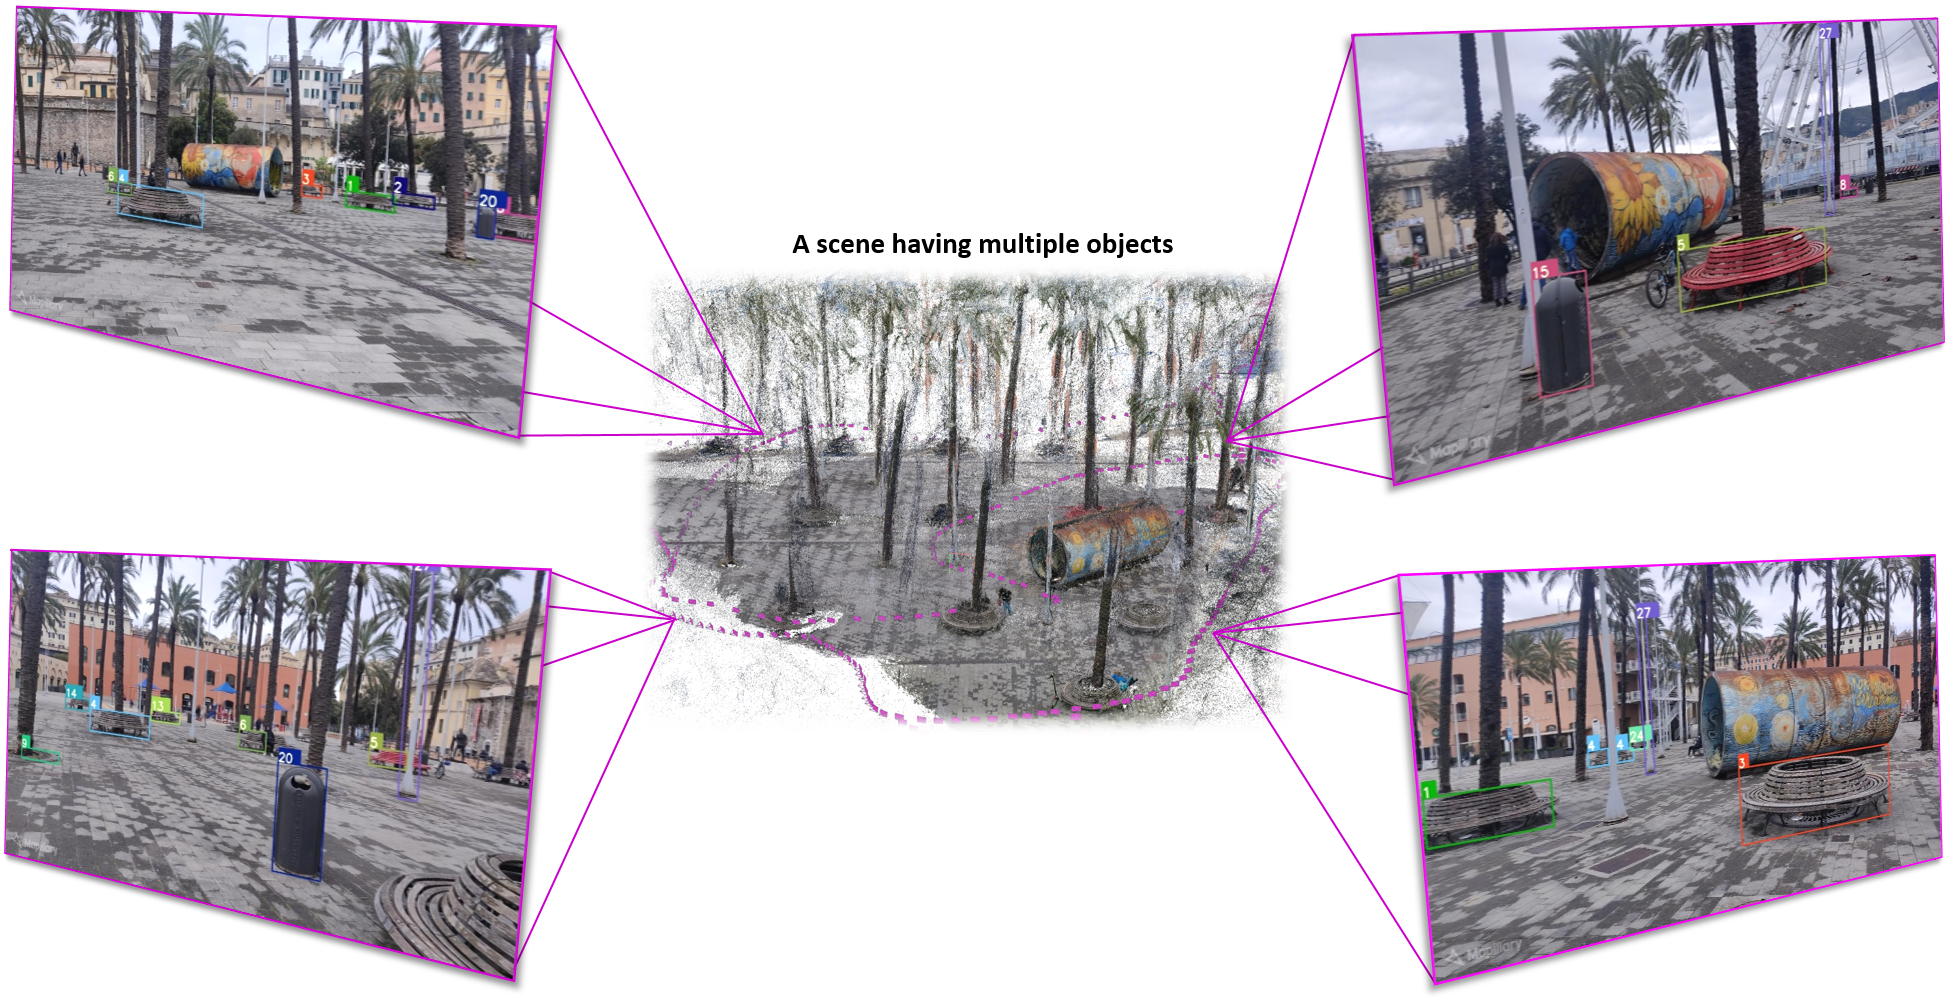
Open the street-scene localization figure

ICIAP · 2022

Multi-view 3D Objects Localization from Street-Level Scenes

Javed Ahmad, Matteo Toso, Matteo Taiana, Stuart James, and Alessio Del Bue

arXiv preprint · 2025

Hands-Free Heritage: Automated 3D Scanning for Cultural Heritage Digitization

Javed Ahmad et al.

Professional Background

Experience

  1. Computer Vision Researcher · DeepPlants

    Sep 2025 – Present · Rome, Italy

    Developing UAV perception and dense reconstruction pipelines for agriculture. Built a mission-control and RGB streaming pipeline on ModalAI VOXL 2 using PX4 and MAVSDK/MAVLink. Conduct field data collection using the DJI Mavic 3.

  2. Postdoctoral Researcher · Italian Institute of Technology

    Feb 2024 – Aug 2025 · Italy

    Advanced Robotics · Genoa, Feb–Aug 2025. SLAM and 3D Gaussian Splatting for teleoperation.

    Center for Cultural Heritage Technology · Venice, Feb 2024–Jan 2025. Robotic artifact scanning and 6-DoF pose estimation.

  3. Doctoral Researcher · PAVIS, Italian Institute of Technology

    Nov 2020 – Dec 2023 · Genoa, Italy

    LiDAR–camera fusion for autonomous driving and multi-view 3D object localization for the EU MEMEX project.

  4. Research and Teaching Assistant · Information Technology University

    Jul 2017 – Oct 2020 · Pakistan

    Research in 3D reconstruction and applied machine learning, with teaching support in machine learning, calculus, and power systems.

Education

  • Ph.D. in Computational Vision, Automatic Recognition, and Learning
    University of Genoa and Italian Institute of Technology · 2023
    Thesis: Multimodal 3D Scene Perception
  • M.S. in Electrical Engineering
    Information Technology University · 2019
  • B.S. in Electrical Engineering
    University of Central Punjab · 2017

Awards

  • First Prize, VISUM Summer School Competition · 2021
  • First Prize, EEML Proposal Competition · 2020
  • Merit-Based Master’s Fellowship · 2017

Technical Skills

Computer vision and learning
Python, PyTorch, OpenCV, Open3D, MMDetection3D
3D mapping and visualization
COLMAP, MASt3R, VGGT, NeRF, 3D Gaussian Splatting, Viser
Robotics and UAVs
ROS 2, MoveIt 2, Pinocchio, UR-RTDE, PX4, MAVSDK/MAVLink, Gazebo SITL

Contact

For research and engineering collaborations in 3D vision, mapping, or robotics, reach me by email or LinkedIn.